




A robot that never steps out of line.
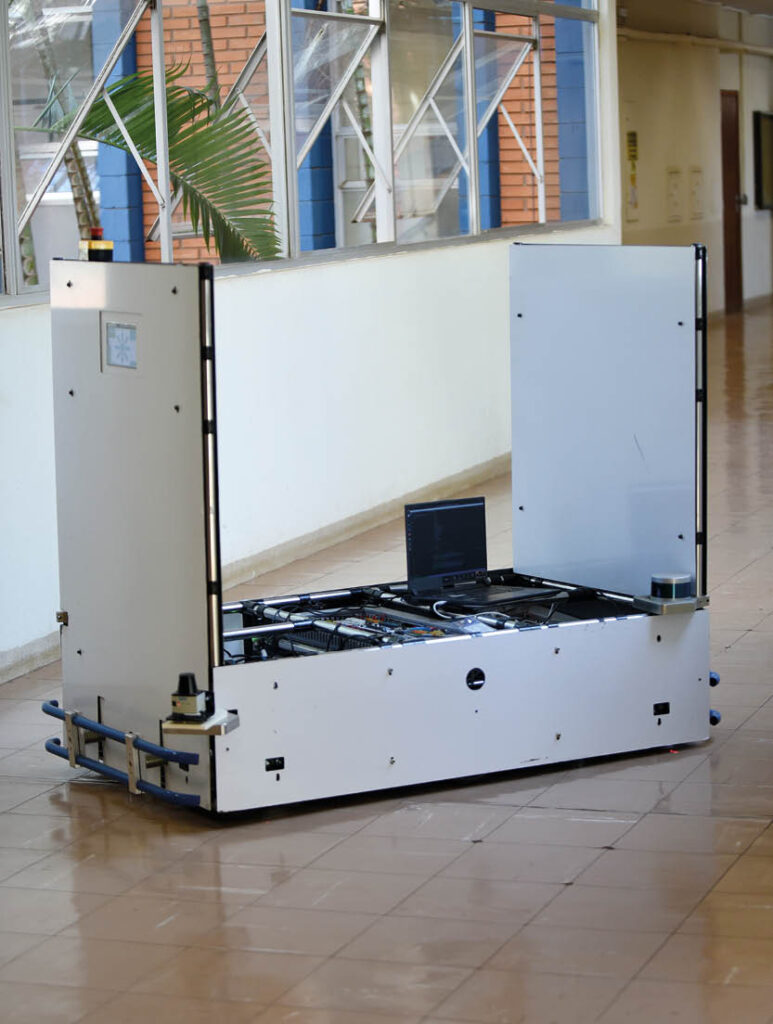
Device developed at FEM moves around the factory following virtual paths defined by software
Moving materials quickly and safely within a factory is one of the most important steps in determining productivity. With this in mind, researchers from the School of Mechanical Engineering (FEM) at Unicamp, led by professor Janito Ferreira, have developed a system that optimizes the transportation of goods at a Samsung unit. The robot is capable of moving autonomously around the factory, safely taking packages to the shipping point.
The project, funded through incentives from the Computer Law, has the main objective of updating the technology of some of the robots used in factories. Robots are usually devices that move along directional lines glued to the floor. This method of tracking can fail if these lines are damaged, such as detachment, erasure or stains. Furthermore, in more dynamic factory environments, where there is frequent reformulation of spaces and logistics, it becomes necessary to constantly reapply these lines.
The new device, in turn, moves along virtual lines defined by software. According to Professor Rodrigo Bacurau, from the Department of Computational Mechanics at FEM, the first time it moves through the environment – manually, with the help of a remote control – the robot examines the walls and obstacles along the way, creating a map that is then saved in a digital file. “With this, you can import the map into an image editing program and draw the paths you want the robot to follow, using lines that emulate those on the floor. The advantage is that these lines do not get damaged or dirty and their trajectory is much easier to reconfigure,” explains the professor.
In addition to researchers from Unicamp, the project included the participation of specialists from the Federal University of Itajubá, in Minas Gerais, and the Jorge Tadeo Lozano University (Colombia). In total, ten professionals from the three institutions, including professors and master's and doctoral students, worked in a multidisciplinary manner in areas as diverse as mechanics, kinematics, programming, electronics and embedded systems. There was also an exchange of information between Samsung specialists and the project team, regarding the technology developed and possible adaptations to be applied to their future robots.
Security and displacement
To guarantee the physical integrity of everyone present in these environments, the developed platform moves at a maximum of half a meter per second and has an architecture that provides three levels of security.
At the first level, lidars – remote object distance detection technology – identify the presence of nearby obstacles and stop movement if something is closer than a predefined limit. If this high-level system fails for any reason, the low-level embedded computer system – responsible for controlling the robot's motors – also has distance sensors that trigger the structure to stop. If, even then, there is a safety failure, bumpers on the front stop the movement by electrically disabling the motors.
“The robot must walk in the same environment as the factory workers and, for safety reasons, it was decided that it must not deviate from its path if an obstacle appears, but must stop immediately and only move again when the path is clear,” says Ferreira, the person responsible for transferring knowledge to the company.
According to the professor, one of the main innovations of the robot developed was its ability to achieve precise positioning without the use of global location sensors, such as GPS, and without the use of physical line tracking systems. For this reason, when the project began, the scientists defined the device's location with a maximum error of 30 millimeters as a necessary requirement. At the end of the project, however, they managed to obtain an extremely precise location system, with a maximum error of 5 millimeters.
To make this possible, a technique called sensor fusion was used, which combines positioning information provided by different sensors. In the case of the robotic platform, there are three sources of location: the displacements made by the wheels; the linear accelerations and angular velocities experienced by the robot; and the location obtained from the lidars using the SLAM technique, an acronym in English for simultaneous localization and mapping.
“With this information, we use a Kalman filter, which, based on the location given by each of these systems, performs mathematical calculations to determine the most likely position of the robot. This is the position we use and that is how we achieved accuracy in the location,” says Bacurau.
“Samsung believes in the transformative power of universities in the technology market and we are excited about this new partnership with Unicamp,” said Miguel Lizarraga, Open Innovation Manager at Samsung Brazil.
The professors are already developing other projects in the area of intelligent vehicles within the Autonomous Mobility Laboratory (LMA) at FEM. In one of these projects, improvements are being made to the Intelligent Vehicle of the Autonomous Mobility Laboratory (Vilma), an instrumented Fiat Punto capable of autonomous driving. Among these improvements, the development of a communication system between vehicles (V2V) and vehicle and traffic infrastructure (V2X) stands out, which will help drivers avoid collisions and other accidents.
All autonomous vehicles developed at LMA use the ROS (Robot Operating System) platform as their base, an open-source framework that allows communication between different vehicle modules and the reuse and sharing of code. Experts in ROS, the LMA researchers intend to soon be able to offer training courses on this platform to the academic community.